Avatarkhorn
⚡ Regular
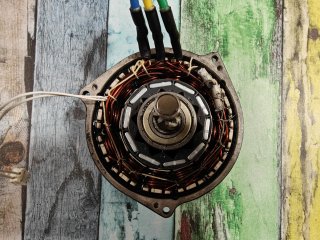
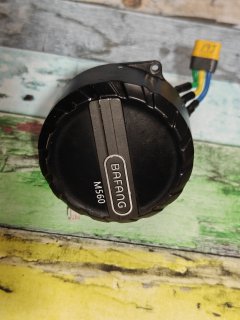
We'll do the math this evening. I have a disassembled M560.Is it known how many pole pairs the M560 has?

We'll do the math this evening. I have a disassembled M560.Is it known how many pole pairs the M560 has?
@stancecokeWe'll do the math this evening. I have a disassembled M560.

Thank you for checking! Then there is no difference in pole pairs to the M510.Five pairs of poles.
Well, the M560 is out of testing because it's bricked. Firmware v0.0075 was successfully loaded. However, due to the settings in v0.006, which was loaded earlier, the motor wouldn't spin in reverse. After I performed a master reset, the controller went to the depths of Valhalla and no longer responds to firmware uploads, neither through BESST nor Canable.I guess, we have to crosscheck all pin functions on the M560, if the behavior is that unpredictable, there must be differences to the M510

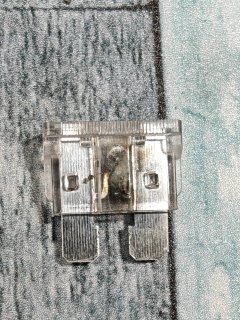
The brown alarm is canceled. The fuse has tripped. I didn't think about it because I didn't see any signs of a large current flowing. I was confused by the lack of the typical spark from a DC-DC converter when the connector is connected to the battery.Flash it with ST-Link V2
You can configure it for each level already by the override thresholds. Only the duration is the same for all levels. But you are right, there are enough fields left in the torque table. But using them will be confusing for the users, as they are not per level, but per speed range in the GUI. Of course we can use them for anything we want, but if the use is too unintuitive, potential users will be put offI'd still like to configure the overrun function as a separate assist mode for difficult climbs.

I'll think about it when I have a graphical interface in front of me.Perhaps you can make a suggestion, how the overdrive should be settable in the GUI.
Do you need to get a 560, the early motors had M510 controllers. Why not get a M560 controller and fit it to your M510, the mechanicals of the two motors must be similar in layout. If you want to go down that route I have a new M560 controller here you can test ( I had intended to fit it to my M510 as some have already done to get the higher hard coded Amps ). With your FOC we can set the amps via Canable.You can configure it for each level already by the override thresholds. Only the duration is the same for all levels. But you are right, there are enough fields left in the torque table. But using them will be confusing for the users, as they are not per level, but per speed range in the GUI. Of course we can use them for anything we want, but if the use is too unintuitive, potential users will be put off
Perhaps you can make a suggestion, how the overdrive should be settable in the GUI.
Good to hear, that the M560 is not dead, thank you for testing! But I will have to get a M560. Development from the distance will not work...
me tooBut I'm surprised this feature has generated the most active discussion and interest.
. I’d call it a bug rather than a feature . But it is discussed widely as Bosch promotes the "extended boost" as an USP (Unique Selling Point)Thank you, but I'm getting help from Windmeile.com already!If you want to go down that route I have a new M560 controller here you
I wanted to do the same thing when I bought the M510. I thought the maximum current was hardcoded into the M510 firmware. However, this isn't the case, and I set it to 20A in the stock firmware (Canable, old BESST) without any problems. Now I'm not sure about replacing the controller, as the M510's power is limited by its smaller physical size, peek gear, and overheating, not the controller.( I had intended to fit it to my M510 as some have already done to get the higher hard coded Amps )
Is it the same, that was shown in this thread several times by @mk00 and @Avatarkhorn?I have a new M560 controller here
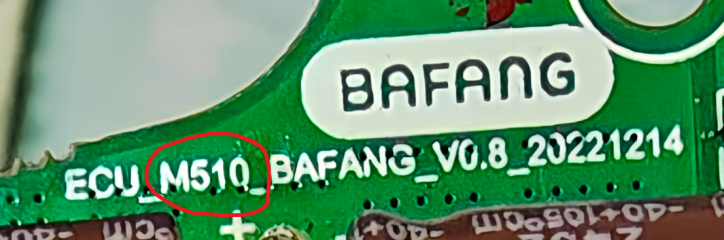
Is it the same, that was shown in this thread several times by @mk00 and @Avatarkhorn?
Mmmm I tried that but didn't seem to work. I'll revisit.and I set it to 20A in the stock firmware (Canable, old BESST) without any problems.
I got a M560 on my workbench now. I had to disable the shut off algorithm (as I have no display connected and the controller switched off randomly) and increased the deadtime of the PWM a little (just because both testers reported random high current peaks), but the position sensor calibration went fine and the motor runs without load with the throttle flawlessly. I've flashed the firmware with the STLink directly to the standard start adress 0x08000000. Maybe the bootloader causes some trouble. We have to test much more, but there are first positive indications with the M560!Do you need to get a 560
I checked most signals now, flashed by the canable tool with the Bootloader 38 and found no abnormal behaviour. Position sensor calibration worked, throttle works, cadence and torque reading works. But I have not tested under load so far, as I have not assembled the M560 on my test bike yet.Maybe the bootloader causes some trouble
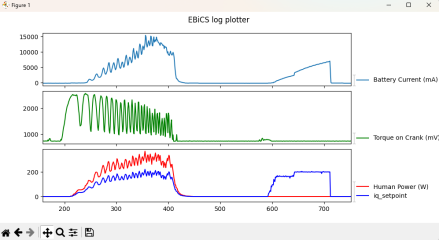
I'll go get my M560 ready for roasting.I've pushed the last changes to a new M560 branch
This time, nothing burned out. The controller freezes. Calibration was successful, Cal = 0. Short pulses are periodically sent to the motor. This is due to the controller sometimes reading more than 750 mV from the torque sensor. It also draws current when idle. None of this happens in the original firmware.I'll go get my M560 ready for roasting.
Thank you for testing! What do you mean with "freezes"?The controller freezes.
The calories field doesn't show the position sensor calibration any more. At the moment it shows the backwards pedaling flagCal = 0
This happens a short time after power-on. It doesn't switch support modes. It doesn't switch information displays for ODO, Cadence, etc. Only power-off works normally.Thank you for testing! What do you mean with "freezes"?
Not less than 2000 mV. Most modes = 3400 mV.What is your setting for the override thresholds?
It seems the motor doesn't know about this restrictionThe motor shouldn't engage, if the torque rises above 750mV, when the torque override threshold is set to a higher value.
Strange, this doesn't happen with my system.It doesn't switch support modes. It doesn't switch information displays for ODO, Cadence, etc. Only power-off works normally.
i_q_setpoint = assist level * filtered torque * cadence^(1/(1+value))This will be difficult, since the only cable supporting throttle is on the bike with the M510. I'll be able to answer this question tomorrow morning.Can you attach a throttle? I wonder if this motor jerks happen because of an open throttle connector.
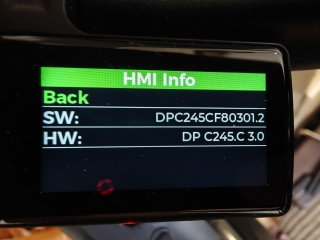
Do you have a different display on the M510 bike also? This freezing may be a matter of the displays firmware also. There is no difference in CAN communication between the M510 and M560 branch.since the only cable supporting throttle is on the bike with the M510
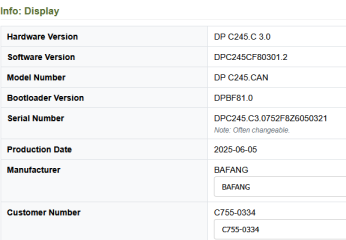
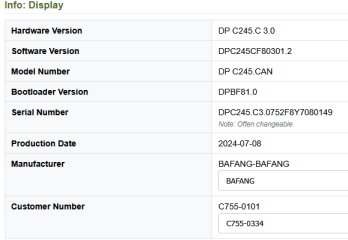
The displays are identical. I'll test the M560 first with a different cable, and then with the throttle handle.Do you have a different display on the M510 bike also? This freezing may be a matter of the displays firmware also.
@stancecoke,The displays are identical. I'll test the M560 first with a different cable, and then with the throttle handle.