It's send as controler temperatue, motor temperature is empty.is it sent over the CAN in a different format ?

You are using an out of date browser. It may not display this or other websites correctly.
You should upgrade or use an alternative browser.
You should upgrade or use an alternative browser.
BAFANG M215 (BBS01 CAN bus), M315 (BBS02 CAN bus), M510, M560, M820, CR-A101 FOC Open Source EBiCS Firmware for GD32F303 processors
- Thread starter stancecoke
- Start date

stancecoke
🏍️ Giga poster
Maybe the M820 has no NTC on the motor at all?motor temperature is empty.
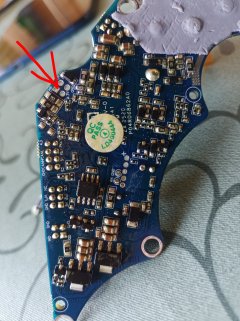
The imprints on the PCB are completely different from the M510. And one connector is not populated at all...
Correct. Power throttling is based on controller temperature here.Maybe the M820 has no NTC on the motor at all?
Waynemarlow
🚴♂️ Mega poster
In some ways thats a pity as knowing what the motor itself is doing is fairly essential in my view.Correct. Power throttling is based on controller temperature here.
Avatarkhorn
⚡ Regular
Testing #5.1OK, thank you for the feedback! Are the power drops solved with this value
Bafang M510 FC 3.0 | Throttle – not used. | Battery – 52v (14S).
DPC245 Screen | FW - EBiCS_for_M510_BL38_v0.0071
1) The motor was calibrated multiple times using EBiCS. Calibration debug values are 63-65.
2) The motor still loses power at high cadence, but to a lesser extent. Up to 600-700W. This is probably the maximum positive result for a calibration with a +60 offset.
Incidentally, calibration in the original Bafang firmware occurs at a current above 1A. The sensors record ~65-75 RPM on the chainring. However, before this, a brief but loud shift in the chainring is observed.
Attachments
Last edited:
stancecoke
🏍️ Giga poster
Yes, looking at your logs, the new calibration value has not fixed the issue, U_d is still much too high.The motor still loses power at high cadence
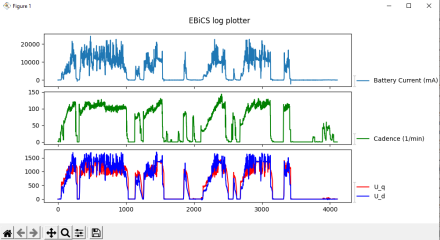
It's not easy to debug, as my motor behaves different obviously.
Using higher current for the calibration is very easy. But it will not solve the problem I guess...
I have to review the algorithm.

Avatarkhorn
⚡ Regular
We still have slightly different controllers. Maybe if I burn out my FC 3.0, I'll have to install a controller from the M560 or FC 2.0It's not easy to debug, as my motor behaves different obviously.
 (I don't see FC 3.0 in the quick access list).
stancecoke
🏍️ Giga poster
Hm, there is a bug in the logic, indeed. The rotor position is calculated from the timer2 value times the angle increment for one encoder step in normal motor operation. If the z-pulse is fired, the timer2 is reset to the value that was found in the calibration procedure for the z-pulse position.I have to review the algorithm.
But I took the z-position from the timer2 value, not from the absolute angle before. So there was a shift in it.
I have to test the new logic on Monday
change in calibration logic · EBiCS/BAFANG_GD32F303RCT6@89d0a89
Firmware for Bafang E-Bike controllers with GD32F303 processors - change in calibration logic · EBiCS/BAFANG_GD32F303RCT6@89d0a89
 github.com
stancecoke
🏍️ Giga poster
OK, the effect of the different way of setting the calibration value is, that I have 180 deg offset now, so the motor is turning in the other direction.I have to test the new logic on Monday
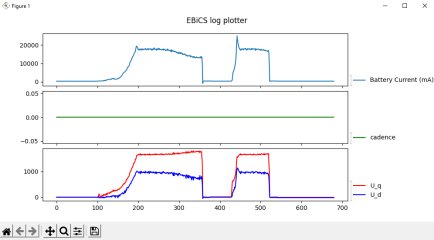
I've added an autotune algorithm now, that starts the motor in closed loop, after the open loop z-position detection has finshed. The motor runs in idle speed now and tunes the found z-position until u_d is slightly negative. You can follow this procedure by watching the calories field. After this tuning, the motor stops and the calibration is finished.
I don't know, why this fine tunig is needed, perhaps the encoder has a certain delay, that needs to be accounted in the rotor angle estimation.
As always, I can test only with my own motor, if you are executing the calibration, make sure, that you have a fuse between battery and controller and have the possibility to cut the supply, if the motor doesn't stop the calibration process...
Before running the position sensor calibration, set the motor directon to the other direction, or do a factory settings reset!
I'll attach the bin file with the latest improvements later!
Avatarkhorn
⚡ Regular
I had the same thing when I first loaded EBiCS onto a motor calibrated with the original firmwarethat I have 180 deg offset now, so the motor is turning in the other direction
stancecoke
🏍️ Giga poster
Here is a video of the calibration process, the calibration value (encoder offset) is shown in the field "Calories". During the open loop calibration, there is no display communication, therefor the display shows an error. The error disappears when the closed loop part of the calibration starts.I'll attach the bin file with the latest improvements later!
After this calibration, U_d is near zero at idle run. Of course without load, the battery current stays near zero also:
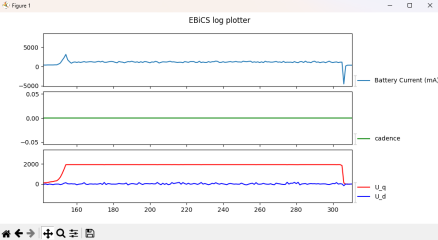
When pedaling with load on the roller trainer, U_d stays in a range, that doesn't hit the U_d max limit at high cadence and high power.
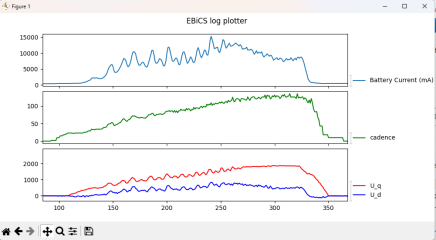
@Avatarkhorn: I'm really curious to see if your logs will look similar now!
Attachments
Last edited:
Avatarkhorn
⚡ Regular
I'll do the calibration, but the field test might have to wait until tomorrow. Yesterday was an epic pig-ride in the mud, and I won't have time to get the bike ready for firmware testing today.@Avatarkhorn: I'm really curious to see if your logs look similar now
Upd.
@stancecoke: I got a rather disappointing result: strange readings, a roaring motor, and currents up to 2.6A. This was true both in one direction and the other, i.e., from the motor to the battery.
Last edited:
stancecoke
🏍️ Giga poster
Hm, your system has a negative Z-position. I have to check, if my calculation fails for negative valuesI got a rather disappointing result:
.But first I will check, if something went wrong with merging the code for compiling it on my other computer.
It took me over 10 calibrations to get stable readings in the 63-65 range. The starting value was 124, then 140+, then 90+, and then gradually decreased to the stable values described above.
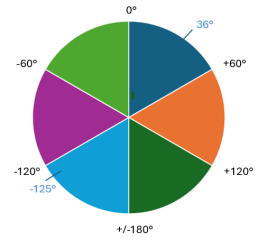
Hm, I have no idea why your offset readings are that random. With the new logic (without the hardcoded 60 offset) the initial value should be about -180 deg, but your video shows about -128 deg. ((65243-2^16)*0,439)1) The motor was calibrated multiple times using EBiCS. Calibration debug values are 63-65.
2) The motor still loses power at high cadence, but to a lesser extent. Up to 600-700W. This is probably the maximum positive result for a calibration with a +60 offset.
I can't find an obvious bug in the calculation. Can you repeat the calibration a few times, to see if you get the same (bad) result always? I've increased the current during the open loop run already in V0.0072, it should be about 5 amps now...
For my motor I find a calibration value of about 82, 82*0,439=36 deg.
Last edited:

TPEHAK
🚴♂️ Mega poster
There is no stator temperature sensor in Bafang M820 motorMaybe the M820 has no NTC on the motor at all?
The imprints on the PCB are completely different from the M510. And one connector is not populated at all...
View attachment 386544
stancecoke
🏍️ Giga poster
Can someone provide a flash dump of the Bootloader 38 for the M510? I tried a modified file from the hubmotor controller, but my mod doesn't work.We still have slightly different controllers.
For the M820 we will have to check, if we can flash a custom firmware with the same strategy. I did a flash dump from the M820 controller and can see, that it uses a different bootloader, the start address has a different offset.
But perhaps, here the guys from the Fake Taxi project like @rekrezeb can help, as they obviously know, how the bin file has to be structured, to be able to flash it with the BESST tool.
Last edited:
Avatarkhorn
⚡ Regular
Of course, I can do it again. But I've calibrated at least five times with the same result. It's just that the video only shows the very first one.Can you repeat the calibration a few times, to see if you get the same (bad) result always?
stancecoke
🏍️ Giga poster
Hm, I've checked the bin file (for bootloader 3) and it works as expected for me.But first I will check, if something went wrong with merging the code for compiling it on my other computer.

I allways get very similar resulte of 82-84 for the calibration value...
So I really wonder, what's going wrong with your motorBut I've calibrated at least five times with the same result.
More Beta users would be helpful, to see if it is a lucky punch with my controller, or if your controller is the exot
Ah, I just have an idea, maybe the timer can't be preloaded with a negative value, I have to check that, but this should be quite easy to solve...
Last edited:
Avatarkhorn
⚡ Regular
My motor is fine. FC 3.0 works almost perfectly. There are just a couple of minor issues due to the proprietary firmware. And that annoying fact of it being proprietarySo I really wonder, what's going wrong with your motor
.I reset the settings just in case and recalibrated several times: the results are stable, the same as above.
stancecoke
🏍️ Giga poster
Maybe, this solves the problem, if the calibration value is negative, it is shifted by one electrical revolution (820 encoder steps) into the positive range. Just one line of codethe results are stable, the same as above.
Would be glad, if you could test it!
Attachments
Avatarkhorn
⚡ Regular
It looks like you did everything correctly! Of course, I'm getting a different value than you. The engine sound and current consumption at idle are adequate.Would be glad, if you could test it!
I'll try to get out on the bike today. Especially since it's not raining yet.
stancecoke
🏍️ Giga poster
Great!It looks like you did everything correctly!
The bug was my fault, I was writing a signed 32 bit integer into a 16 bit register I will better do a cast to avoid further trouble!Avatarkhorn
⚡ Regular
Testing #6Would be glad, if you could test it!
Bafang M510 FC 3.0 | Throttle – not used. | Battery – 52v (14S).
DPC245 display | FW - EBiCS_for_M510_BL38_v0.0073
1) The motor runs perfectly: very quiet, smooth, and powerful. Calibrated successfully on the first try. Perhaps the current calibration algorithm is perfect; more testers are needed.
2) The adequate range of assistance levels on my motor is quite small. Roughly speaking, ~30-100 units. At 75, I can easily reach maximum power (factor *1).
3) CANable Pro algorithms interfere with adjusting the Torque Sensor filter. It is forbidden to set the acceleration in ECO mode higher than in more powerful riding modes. And since In EBiCS, the higher the value, the stronger the filtering, so it's impossible to make ECO smoother.
4) All other comments concern features that haven't been implemented yet; I hope we can move forward now.
I think I can now use this build permanently on my M510.
Attachments
stancecoke
🏍️ Giga poster
I hope @mdi will disable the value check in the Canable tool, I don't want to have an extra tool.CANable Pro algorithms interfere with adjusting the Torque Sensor filter.
Hm, of course I can reduce the output. As I don't know, how much torque one amp of motor current produces, I can't really calculate the mechanical power. I would simply reduce it by factor four, then you have a bigger number range for fine tuning.The adequate range of assistance levels on my motor is quite small.
We can add any gimmick we want, but we have to prioritise: is it more helpful to make other motors like the M820 work, or to add more functions to the M510?All other comments concern features that haven't been implemented yet;
We had the statement, that in the M560 exactly the same controller is used as in the M510 from @Avatarkhorn. But we got a report about melted battery contacts on the M560 also.I could also test but at the moment I only own a m560 so it's not helping right ?
I have no M560, so I can't test.
Avatarkhorn
⚡ Regular
Of course, I'd love to get functional firmware for my motor faster. But more motors = more testers. And there aren't that many popular models: M510, M560, M820.is it more helpful to make other motors like the M820 work, or to add more functions to the M510?
I didn't say thatWe had the statement, that in the M560 exactly the same controller is used as in the M510 from @Avatarkhorn.
.They are identical and the first versions of the controllers used the same board.
However, I would like to test it first through the fuse. I already have that capability.
