Technical Update: DM02 (500W) Firmware Optimization

Here you can see the issue, with that firmware appeared also that noise seems a frog
Thanks for the quick update, Mr. Stefano.

Our tech team took a look at the video. Since the noise happens even when the bike is completely still, we strongly suspect it's a Torque Sensor zero-point calibration issue. In standby mode, the controller may be picking up unstable torque signals, which makes the PWM send tiny pulses to the motor coils.

Could you please record a short video of the display starting from the moment you turn the bike on? So that we can make sure to send you the right solution.

We recommend putting the bike on its kickstand and making sure no weight or pressure is on the pedals or cranks while the system boots up.

We really want to get this properly sorted for you. Please share with us what you find!

Toseven Supoprt Team
 
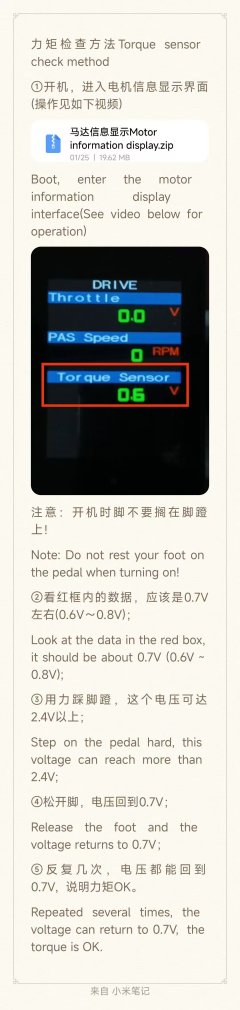
Torque sensor is showing incorrect value 1.7V. It should be ~0.7V. Did you have the same issue before installing new firmware (2026-05-26)?
Dear Mr. Snajpera,

Thanks for your feedback. That's an interesting observation about the voltage variance.

To help our tech team figure out what's going on and get to the real root cause, could you please send a quick video of your display starting from the very moment you turn it on? That’ll give our engineers the exact data they need to cross-check.

Thanks for sharing all the details. Looking forward to your video!

Toseven Support Team
 
Dear Mr. Snajpera,

Thanks for your feedback. That's an interesting observation about the voltage variance.

To help our tech team figure out what's going on and get to the real root cause, could you please send a quick video of your display starting from the very moment you turn it on? That’ll give our engineers the exact data they need to cross-check.

Thanks for sharing all the details. Looking forward to your video!

Toseven Support Team
Another example why you should stop using AI for communications with your customers. Your AI SLOP agent completely got lost here and didn't figure out that It was just a comment to Stefano's issue. Real human would not make that silly mistake here.
 
Last edited:
Thanks for the quick update, Mr. Stefano.

Our tech team took a look at the video. Since the noise happens even when the bike is completely still, we strongly suspect it's a Torque Sensor zero-point calibration issue. In standby mode, the controller may be picking up unstable torque signals, which makes the PWM send tiny pulses to the motor coils.

Could you please record a short video of the display starting from the moment you turn the bike on? So that we can make sure to send you the right solution.

We recommend putting the bike on its kickstand and making sure no weight or pressure is on the pedals or cranks while the system boots up.

We really want to get this properly sorted for you. Please share with us what you find!

Toseven Supoprt Team
Here a timelapse from the switching on, you can see the voltage start from 0.7v and raise to 1v in only 3/4 minutes of riding. You can imagine how fast and easy is to raise to 1.7v.
 
i see that nobody of toseven is no longer intrested in their products issue...
it's about 1 year i'm having this issue... voltage on torque sensor is rising during ride. it mean ghost pedals, the bike go to full power only spinning slowly the pedals, in some case it's very dangerous.
I spoke with toseven on endlesssphere forum, they said: "don't worry we will help you!"
when i said i purchased the DM02 from RECYCLES-EBIKE store on aliexpress they said: "deal it with them" (what a big help!!!)
It's about 2 months that the seller is only able to ask and tell me (once every 3 days) a lot of bullshits. I sent video and video showing the issue. they was able only to send the update file that i already tried with no results.


I know the seller only wants to reach the date of the end of warranty (end of august) to tell me "frock you, no longer my issue".


IS THIS THE LEVEL OF WARRANTY YOU GIVE TO CUSTOMERS???
 
i see that nobody of toseven is no longer intrested in their products issue...
it's about 1 year i'm having this issue... voltage on torque sensor is rising during ride. it mean ghost pedals, the bike go to full power only spinning slowly the pedals, in some case it's very dangerous.
I spoke with toseven on endlesssphere forum, they said: "don't worry we will help you!"
when i said i purchased the DM02 from RECYCLES-EBIKE store on aliexpress they said: "deal it with them" (what a big help!!!)
It's about 2 months that the seller is only able to ask and tell me (once every 3 days) a lot of bullshits. I sent video and video showing the issue. they was able only to send the update file that i already tried with no results.


I know the seller only wants to reach the date of the end of warranty (end of august) to tell me "frock you, no longer my issue".


IS THIS THE LEVEL OF WARRANTY YOU GIVE TO CUSTOMERS???
Dear Customer,

We hear you, and we sincerely apologize for the frustration and repeated delays you’ve experienced over the past few months.

As a manufacturer, our standard workflow is to have direct sales partners, such as AliExpress stores, handle frontline customer service, since they manage order logistics and local warranty support. However, when communication breaks down as it did in your case, and safety is involved, we will not stand by and do nothing.

Regarding your DM02 purchased in mid-2025:

The thermal drift issue you reported has been addressed in our updated controller firmware logic. We noticed that you tried an earlier update file with mixed results; this is often related to threshold calibration mappings on earlier production hardware batches.

To move forward efficiently, please run the torque sensor diagnostic test shown in the attached file and email the results along with your order details to support@to7motor.com. Once we verify the results, if a hardware replacement is needed, we will dispatch it directly to you from our factory.

We truly value our community members on Endless Sphere, and we are committed to making sure your DM02 is tuned to run safely and properly.

Toseven Support Team
 

Attachments

  • Torque sensor testing .jpg
    Torque sensor testing .jpg
    666.6 KB · Views: 6
Another example why you should stop using AI for communications with your customers. Your AI SLOP agent completely got lost here and didn't figure out that It was just a comment to Stefano's issue. Real human would not make that silly mistake here.
Oh yeah, totally misread that thread, our bad. Thanks for the catch; appreciate it.:)
 
Dear Customer,

The firmware on our website is already the latest version. Thanks.

Toseven Support Team
2 months old. I'm asking about something newer which addresses known issues like how motor cuts power at set speed limit (for example 25 km/h ). There is also a noticeable lag before motor re-activates.
 
2 months old. I'm asking about something newer which addresses known issues like how motor cuts power at set speed limit (for example 25 km/h ). There is also a noticeable lag before motor re-activates.
Dear Customer,

Thanks for reporting this; our tech team is looking into it.

We'll post an update here once we have a fix or a test firmware ready.

Toseve Support Team
 
Suggestion for new firmware

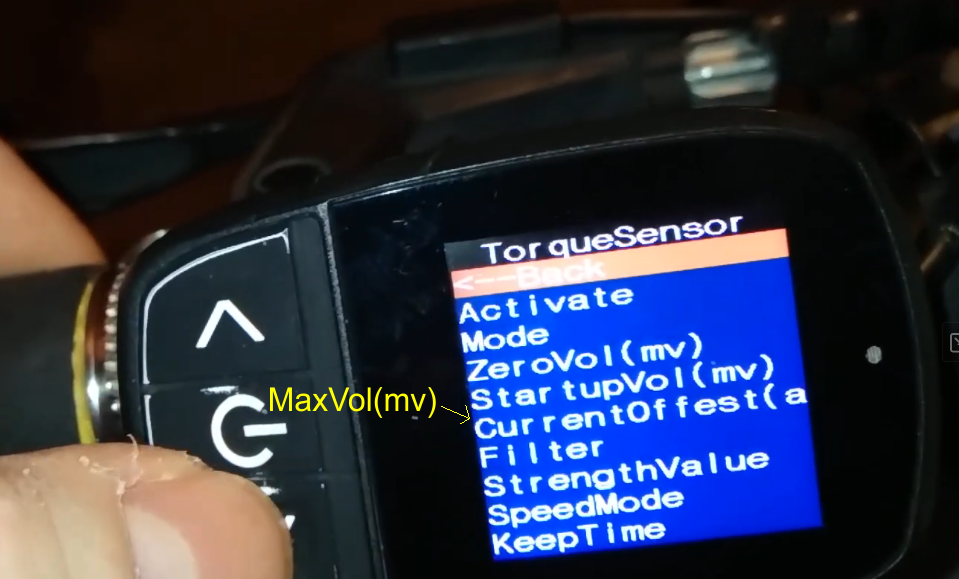
In torque sensor section add MaxVol(mv) option

Untitled-1.png


Reason
We as community on dedicated discord channel have established that not every torque sensor acts in the same way.
Some users report that they can reach max 3.0V relatively easily just by pressing harder on the pedal with their foot while standing still.
However my torque sensor appears to be less sensitive. I have to put a lot of force to reach 2.0V.


The highest value I have seen while riding uphill without assist was 2.5V.
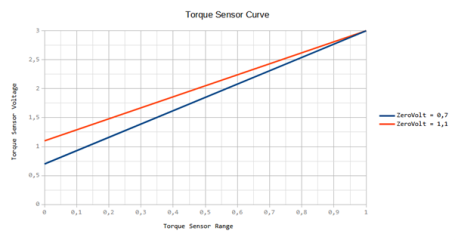
I believe that firmware uses fixed 3.0V as max for assist curve.

Picture178.png

Added MaxVol option would allow me to compress whole range according to real max value I can achieve on my torque sensor. So instead of 3.0V I would like to set max to 2.5V. This would give me a better dynamic response.
 
Last edited:
Suggestion for new firmware

In torque sensor section add MaxVol(mv) option

Untitled-1.png


Reason
We as community on dedicated discord channel have established that not every torque sensor acts in the same way.
Some users report that they can reach max 3.0V relatively easily just by pressing harder on the pedal with their foot while standing still.
However my torque sensor appears to be less sensitive. I have to put a lot of force to reach 2.0V.


The highest value I have seen while riding uphill without assist was 2.5V.
I believe that firmware uses fixed 3.0V as max for assist curve.

View attachment 391964

Added MaxVol option would allow me to compress whole range according to real max value I can achieve on my torque sensor. So instead of 3.0V I would like to set max to 2.5V. This would give me a better dynamic response.
Dear Customer,

Thanks for the detailed feedback. We actually saw this same old-vs-new sensor difference during our own R&D and production runs.

There are two different things here: the sensor's hardware output range, and how the controller interprets that signal for torque calculation and assist.

The analog front-end outputs roughly 0–3.3 V. Zero point depends on the sensor and calibration. The 3.3 V ceiling is from the analog circuit, not a firmware limit at 3.0 V.

We've changed the sensor characteristic over time. Earlier batches were more sensitive; users could reach the upper range with light pedaling. Strong assist feel, but the response wasn't as predictable as we wanted.

Newer calibration uses lower sensitivity and a wider linear range. Takes more pedal force to hit 3.0 V or above, which gives users better resolution across normal pedaling forces, and the assist feels smoother and more progressive.

On the "MaxVol" adjustment question:

When the DM motors first launched, we made many parameters adjustable, thinking power users would appreciate the flexibility. But after seeing many real-world cases, we also learned that some problems could be caused by parameter combinations that pushed the system outside its intended operating conditions.

The problem is that these parameters aren't independent.

Change torque scaling, and you change how pedal force maps to calculated torque, which changes assist and current draw. Factor in gearing, cadence, rider weight, terrain, a small adjustment can significantly change thermal and mechanical loads on the motor and gears.

And when something breaks, it's hard to tell from the outside if it was a component issue, a config issue, or both.

So we made a deliberate engineering decision: not every internal parameter needs to be user-tunable.

Not because we don't value community input; on the contrary, we do, and we rely on it. But we'd rather keep complex calibration on our side, so the user-facing system stays robust and predictable.

Of course, we should definitely do a better job documenting the recommended settings. But docs and user-accessible tuning are separate things. Some parameters are fine for diagnosis or factory use without being appropriate as everyday user settings.

In other words, we don't want to give riders access to every internal parameter just for the sake of having more settings. We would rather make sure the system works correctly without requiring the rider to understand or manage those parameters.

That's why we prefer handling torque sensor characteristics through controlled calibration strategies, rather than asking riders to manually tune a "MaxVol" value without knowing the exact characteristics of their individual sensor.

We do see value in providing diagnostic or calibration tools for advanced users and technicians. But for the average rider, we believe a motor that is properly calibrated and validated from the factory provides a much better experience than one that requires the rider to engineer the system themselves.

We'll pass your suggestion to our firmware team and consider whether there is a better way to compensate for unit-to-unit sensor variation.

And we really appreciate the thorough testing you've done on our DM system and the time you've taken to share your findings. This is exactly the kind of technical feedback that helps us keep improving our motor products.


Toseven Support Team
 
Dear Customer,

Thanks for the detailed feedback. We actually saw this same old-vs-new sensor difference during our own R&D and production runs.

There are two different things here: the sensor's hardware output range, and how the controller interprets that signal for torque calculation and assist.

The analog front-end outputs roughly 0–3.3 V. Zero point depends on the sensor and calibration. The 3.3 V ceiling is from the analog circuit, not a firmware limit at 3.0 V.

We've changed the sensor characteristic over time. Earlier batches were more sensitive; users could reach the upper range with light pedaling. Strong assist feel, but the response wasn't as predictable as we wanted.

Newer calibration uses lower sensitivity and a wider linear range. Takes more pedal force to hit 3.0 V or above, which gives users better resolution across normal pedaling forces, and the assist feels smoother and more progressive.

On the "MaxVol" adjustment question:

When the DM motors first launched, we made many parameters adjustable, thinking power users would appreciate the flexibility. But after seeing many real-world cases, we also learned that some problems could be caused by parameter combinations that pushed the system outside its intended operating conditions.

The problem is that these parameters aren't independent.

Change torque scaling, and you change how pedal force maps to calculated torque, which changes assist and current draw. Factor in gearing, cadence, rider weight, terrain, a small adjustment can significantly change thermal and mechanical loads on the motor and gears.

And when something breaks, it's hard to tell from the outside if it was a component issue, a config issue, or both.

So we made a deliberate engineering decision: not every internal parameter needs to be user-tunable.

Not because we don't value community input; on the contrary, we do, and we rely on it. But we'd rather keep complex calibration on our side, so the user-facing system stays robust and predictable.

Of course, we should definitely do a better job documenting the recommended settings. But docs and user-accessible tuning are separate things. Some parameters are fine for diagnosis or factory use without being appropriate as everyday user settings.

In other words, we don't want to give riders access to every internal parameter just for the sake of having more settings. We would rather make sure the system works correctly without requiring the rider to understand or manage those parameters.

That's why we prefer handling torque sensor characteristics through controlled calibration strategies, rather than asking riders to manually tune a "MaxVol" value without knowing the exact characteristics of their individual sensor.

We do see value in providing diagnostic or calibration tools for advanced users and technicians. But for the average rider, we believe a motor that is properly calibrated and validated from the factory provides a much better experience than one that requires the rider to engineer the system themselves.

We'll pass your suggestion to our firmware team and consider whether there is a better way to compensate for unit-to-unit sensor variation.

And we really appreciate the thorough testing you've done on our DM system and the time you've taken to share your findings. This is exactly the kind of technical feedback that helps us keep improving our motor products.


Toseven Support Team
Why not limit how much user can change in MaxVol option? You already have similar limitation in ZeroVol. We can't set there any value for obvious reasons. Limited range from 2.5V to 3.3V should not cause any issues. Currently my Dm02 does not provide enough power when I press really hard on pedals. I believe it is caused by the fact that firmware sees my max input only at ~80%.
 
Last edited:
Why not limit how much user can change in MaxVol option? You already have similar limitation in ZeroVol. We can't set there any value for obvious reasons. Limited range from 2.5V to 3.3V should not cause any issues. Currently my Dm02 does not provide enough power when I press really hard on pedals. I believe it is caused by the fact that firmware sees my max input only at ~80%.
Dear Mr. Snajpera,

Thanks for the detailed follow-up. Your reasoning about MaxVol is understandable from a calibration perspective, and we understand why you would prefer to have a controlled adjustment range rather than an unrestricted parameter.

If your sensor's actual maximum output is significantly below the current MaxVol reference, reducing MaxVol could indeed change how that available signal range is mapped to the torque percentage. But this would not increase the physical output of the torque sensor itself; it would only change the way the firmware interprets the existing signal.

Before concluding this is the reason for the lower assist output, we'd like to separate the sensor's actual output characteristic from the firmware scaling. If you can measure the torque sensor voltage at zero load and under your maximum pedal force, our tech team can see whether your unit is behaving as expected for its sensor generation or whether there is a calibration mismatch.

Regarding adding a user-adjustable MaxVol range, we understand the idea of putting limits around the parameter, similar to ZeroVol. The challenge for us is that MaxVol is currently an internal calibration parameter rather than a general user setting. Different sensor characteristics, assist settings, cadence, gearing, current limits, and mechanical loads can interact, so we have to validate a firmware change across the DM02 platform rather than optimize the firmware for one individual unit.

That doesn't mean we are dismissing the suggestion. On the contrary, if we see the same behavior across multiple DM02 units, especially units using the newer sensor characteristic, then it becomes a product-level issue that is worth addressing in the firmware or calibration strategy.


So rather than creating a special firmware for one motor, we'd prefer to collect real data from cases like yours and use that information to determine whether a future firmware revision or a more controlled calibration method would benefit the wider DM02 user base.

We really appreciate you taking the time to test this properly. Feedback from technically experienced users is gold to us. It's one of the best ways to distinguish between an individual configuration issue and something that needs to be improved at the product level.

Toseven Support Team
 
it would only change the way the firmware interprets the existing signal.

EXACTLY! This is exactly what I want. If my torque sensor maxes out at only 2.4V under heavy pedal force, I want to manually set the endpoint to 2.5V rather than relying on the hardcoded 3.0V–3.3V range. Setting the endpoint lower will allow the firmware to correctly register my input as 100%, prompting the motor to increase power accordingly. For example, under the same pedal RPM and force, this would give me ~300W instead of ~250W.
 
Last edited:
EXACTLY! This is exactly what I want. If my torque sensor maxes out at only 2.4V under heavy pedal force, I want to manually set the endpoint to 2.5V rather than relying on the hardcoded 3.0V–3.3V range. Setting the endpoint lower will allow the firmware to correctly register my input as 100%, prompting the motor to increase power accordingly. For example, under the same pedal RPM and force, this would give me ~300W instead of ~250W.
Dear Customer,
We understand your point now, and that example really helps clarify the calibration thing.

If your sensor is only hitting around 2.4 V at your max pedal force, while the firmware's MaxVol is set way higher, then your usable range might not be getting mapped to 100% torque. Lowering MaxVol could indeed increase the calculated torque % for the same physical input.

But we'd separate that from the power output question. Hitting 100% torque doesn't automatically mean the motor jumps from 250W to 300W; there's still assist mapping, cadence, current limits, battery voltage, and other control logic in the loop.

We think your idea is worth testing for sure. If you can measure sensor voltage at:

no load
strong pedaling
max effort

Please also note what the display shows for torque % and motor power at each point; that will give our tech team a much clearer picture. For instance, if you're seeing ~2.4V but the display says ~80% torque, that's a solid hint that the available range isn't being fully used. From there we can figure out whether it's a MaxVol tweak, a different calibration curve, or a firmware-level change.

On your suggestion about exposing a controlled MaxVol range, we think that's a reasonable discussion to have. The real question for us isn't just whether we can expose it, but whether this same behavior shows up across multiple DM02 units and sensor batches. If it's a consistent pattern, then it becomes a product-level firmware/calibration issue, not just an individual user setting, and that's something our firmware team can properly look into and validate.

Your test results would actually be really useful to figure that out.


Toseven Support Team
 
I believe you as manufacturer has access to way more dm02 units that I will every have in my entire life. Is that hard for you to simply install motor on real bike and see how torque sensor behavies. IT is not a Rocket science.
 
I believe you as manufacturer has access to way more dm02 units that I will every have in my entire life. Is that hard for you to simply install motor on real bike and see how torque sensor behavies. IT is not a Rocket science.
Dear Customer,

Fair point. Our tech team will verify the behavior internally.

On MaxVol, making that a user-adjustable setting is something we need to look at from a product-level perspective. We understand why that would be useful for power users.

But our goal is to make the torque system work correctly without riders having to dial in internal calibrations.

Either way, thanks for raising this and giving us something specific to investigate

Toseven Support Team
 
As I understood it, the DM02 always had an issue with ambient heat raising the voltage level of the torque sensor without a load, causing the motor to activate w/o pedalling when hot, All those early firmware updates were intended to work-around the problem,

Probably the better solution would have been some hardware temperature compensation, but my circuit designer days are long passed. Or you ask the rider to power off and recalibrate the voltage when hot, I dunno, In any case, I haven't come up across this issue in my DM02 which has very early firmware. I don't ride in hot climates.
 
As I understood it, the DM02 always had an issue with ambient heat raising the voltage level of the torque sensor without a load, causing the motor to activate w/o pedalling when hot, All those early firmware updates were intended to work-around the problem,

Probably the better solution would have been some hardware temperature compensation, but my circuit designer days are long passed. Or you ask the rider to power off and recalibrate the voltage when hot, I dunno, In any case, I haven't come up across this issue in my DM02 which has very early firmware. I don't ride in hot climates.
I believe that they already have some sort of compensation based on temperature reported by controller's temp sensor.
Firmware is constantly adjusting zero point. After power-on it is usually around 0.7V. By default motor starts at 0.9V. When motor heats up zero point can go to for example 1.0V so StartVol is now 1.2V. Old firmware did not adjust that. As the result assist from motor was going up with raising rest voltage on torque sensor.
 
I've found another bug in firmware. I've recently performed an update for T154 Display (2026-03-13) and DM02 Controller (2026-05-26) and I noticed that temperature for controller is wrong! Before an update it was always perfect after power-on. Now it shows ridiculous ~50C. No idea if it is a another bug in display's firmware or controller's firmware

IMG-20260919-115842.jpg
 
Last edited:
Back
Top