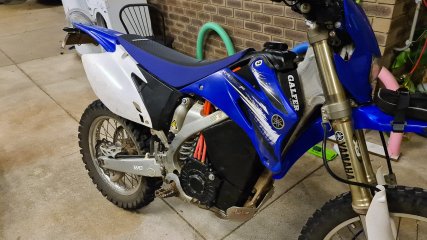
wr250f conversion

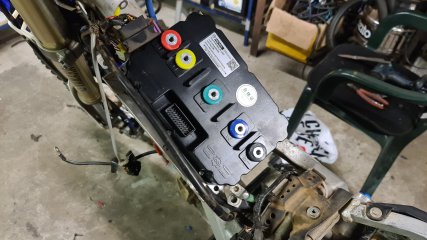
Got a fardriver 961800 to replace the apt 96800. For anyone interested it's significantly smaller, is 4.5kg where the apt is 6.8kg and i had to get it made to suite an encoder instead of hall. Going to need to remake the controller mount, probably a few weeks till going, will be sure to re-dyno.

20220518_182236.jpg

Doug
 
Interesting thread and good call on the fardriver! I could not get my APT96600 to do what i wanted since functionality is blocked in the program without any explanation or means of rounding the block.

I am pretty sure APT controllers are actually good when unrestricted, just by looking at the functions so if anyone finds a seller (not QS) that sells APTs with a full functionality they’d be worth to buy :bolt:
 
I am very interested in what you think and how it turns out :thumb:
I thought I should get a nd1081800 to try, but it seems like the 108 models are unavailable because of mosfet shortage :(
 
j bjork said:
I thought I should get a nd1081800 to try, but it seems like the 108 models are unavailable because of mosfet shortage :(

:thumb: Then get a 1082400 instead :wink:

Or ask here: https://m.alibaba.com/product/1600481288923/Peak-128v-ND1081800-Plus-Fardriver-FOC.html
 
larsb said:
Or ask here: https://m.alibaba.com/product/1600481288923/Peak-128v-ND1081800-Plus-Fardriver-FOC.html

I have asked there, listed on the site but no stock..
 
Should be pretty good, I suppose we'll find out in about 2 weeks when I finish fitting it. I also need to do some other work to get the bike ready for engineering.

I make industrial electronics for work and the chip shortage is a wild ride. Near weekly end of life notifications, lead times over 12 months with no real guarrentee that they will actually be available when the time comes. Lots of re-engineering and in some cases making IC's with descrete parts on a sub PCB. Lots of breathing into brown paper bags :shock: .

Will keep updated about the drive.

Doug
 
Interesting thread and project! I like your dyno. Nice concept and clean build too. Should come in useful for tuning. Have you figured a way to get a hp reading out of it yet?

Years ago we built a dyno using a clamped car torque converter pushing a load cell for the output signal. I never did try to get a hp number out of it as we were using it to see how we were porting VW heads for racing. Ours didn't look near as nice as yours but we did get accurate, repeatable info out of it.
 
The dyno does give power figures, but it's measured by a reaction arm from the brake so its really measuring power at the brake. Minimal loss from rolling resistance means those figures are pretty close to wheel power. My tzr measures around 32kW at the the brake. Thats about 42whp which is pretty close to right given the motor is rated at ~50 crank hp. Its an on going project that got put aside while renovations inside the unit were happening. The brake itself is rated for 1200nm of torque and the drum is balanced to 4000rpm. It's cost about $7kAUD to date so certainly cheaper then buying a dynojet.

Will definitely be putting the wr on it with the new controller. I dont really want a suicide machine so ill probably settle for a lower power then its capable of but im sort of interested in seeing what these motors do when poked with a stick. My battery pack will very quickly become a limiting factor though...will just have to try it and see.

Doug
 
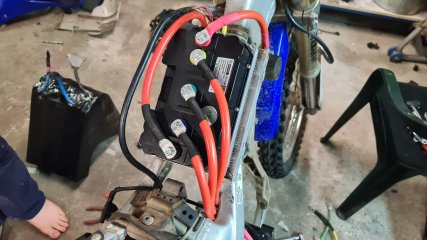
Fitted the new drive today, was easier than anticipated because it was smaller. Also replaced the phase and batt lines with some 50mm2 double insulated high temp orange cable for adr compliance. Much nicer then the factory motor phase wire which is stiff and unruley.

20220520_214834.jpg

Got the basics wired in and did some testing. The controller doesnt like my precharge circuit, maybe a bit slow. It beeps a phase shorted error until i power cycle it with the contactor pulled in. Ran the auto tune and tried to ride it but it would stuttor and cut out with a phase current protect error. Halved the line current max and can ride now with progressive throttle but it accelerates very slowly with a max of about 14kw and aggressive throttle at low speeds still trips it. Im guessing its something to do with the PID params. Ive only used the app so far, will plug it into a PC and have a chat with it. The pc software looks a bit better fleshed out.

Doug
 
Update, went over all the settings with the PC. Some were out according to the manual so i set them to recommended. The default mode is "middle" if low or high are not turned on which explained the sluggishness. I set the bus amps to 600 and phase amps to 1200. Now it peaks around 45kw out of the batt :twisted:. I will get it onto the dyno for some tuning. The rate of increase in power is pretty slow. I believe thats to do with the control PID params. Motor didnt get more then 30deg, phase wires are just above ambient.

20220521_193206.jpg

Doug
 
I peak around 45kw too during field weakening.
(Around 450A and around 110V I think)
But lower up to that.
 
This is off the line, no field weakening. This bike should be fast enough without field weakening. I will go up on the front sprocket for more speed if needed. Remember, thats battery power and i believe its sag compensated. Going by the ~18wkW it made before and assuming no efficency change its probably ~27wkW now. Lots more power up top where the apt was limited to 255pA. I will run it down the drags again, should give a good real world idea of power.

I suppose that means i need to change my tyres over :| should have ordered some supermoto rims.

Doug
 
Is there a reason why you dont want to use field weakening?
Have you been able to tune the throttle response like you want it?
So the computer program has more settings than the phone app?
It seems like they think the other way around in the fardriver thread.

How do you like the controller and program so far?
It says MTPA in the screen on the program, but I havent seen any mention of the controller having it.
Have you seen anything about it?
But I guess then you get field weakening if you want it or not :wink:
 
j bjork said:
Is there a reason why you dont want to use field weakening?
Have you been able to tune the throttle response like you want it?
So the computer program has more settings than the phone app?
It seems like they think the other way around in the fardriver thread.

How do you like the controller and program so far?
It says MTPA in the screen on the program, but I havent seen any mention of the controller having it.
Have you seen anything about it?
But I guess then you get field weakening if you want it or not :wink:

If I didnt need the extra speed I wasnt too conserned. From what I understand It drops efficency and generates more heat. I suppose on the smaller 138 it would be nice to have extra torque down low and still get a higher top speed but I
think this thing makes enough power without it. You are correct, if I set any of the phase % less then 100 above around 5300rpm then it will begin to field weaken. I will play around with it but it's not on the short list.

I think I got the throttle response better....got hard to tell when the wheel would spin at 50kph ;). The actual throttle response time is fine, it was mostly the rate of accelleration that seemed low, However, the phase % started relatively low, peaked at 80% at around 2500rpm, then started tapering down. I upped all the lower % to 80 and now It blows out the rear wheel. I really need to ride it offroad to get a good gauge but it feels at least as good as the APT was. There is a setting in the controller to do with the accel called LM. The manual calls to use it to smooth out hunting in the throttle at steady state. If I lower mine less then 22 (factory max) I trip overcurrnet on the MOS. My guess is that I wont be able to improve the throttle response anymore until I sort out the torque PID loop and the only way Im going to be able to do that is on the dyno.

I do get a bit of throttle hunting at steady state, however, I also got this on the apt when I switched to the magura potentiometer throttle. Had a look at the throttle signal /5v supply and It had about +/-250mV of switcher noise. This would probably be fine with a Hall throttle but not with a pot. I put a crude LC filter on it but it didnt improve. WIll probably need to put a linear 3.3v reg on the 5v output and use that to drive the pot.

PC vs APP, dont think there are any settings that are not available in one and not the other...maybe I have a newer version of the PC software. I find the app convenient on the side of the road, otherwise Im a PC guy.

So far the only issues Ive found are with regen. If I set my regen to throttle release, it works, but when I then bring throttle back on I dont get any throttle for a bit of time, sometimes needing to roll throttle back off and then back on and it will suddenly burst into power randomly. Need to look into it more. APP crashes everytime you save, PC software doesnt.

Some limitations of my drive, I have the encoder version of the drive, means I miss out on the cruise control, but I do get contactor control. I also missed out on CAN which would have been nice but that is probably because I didnt ask for it. The drive talks rs485, I am looking into decoding it to run a dash so I can remove my external shunt and battery SOC system. It might be modbus, was looking at it late last night briefly.

Over all, good upgrade. I really havent stretched it's legs yet. Need a road tire to go any further. new wheelset on order right now so soon.

Doug
 
dougf said:
if I set any of the phase % less then 100 above around 5300rpm then it will begin to field weaken.

Hmm, my fw starts around 2000rpm I think. I defiantly dont have full phase A at 5300rpm

dougf said:
There is a setting in the controller to do with the accel called LM. The manual calls to use it to smooth out hunting in the throttle at steady state. If I lower mine less then 22 (factory max) I trip overcurrnet on the MOS. My guess is that I wont be able to improve the throttle response anymore until I sort out the torque PID loop and the only way Im going to be able to do that is on the dyno.

Is there a logger or something to look at when sorting it out?

dougf said:
Some limitations of my drive, I have the encoder version of the drive, means I miss out on the cruise control, but I do get contactor control. I also missed out on CAN which would have been nice but that is probably because I didnt ask for it.

Sin cos? Or are there more than 2 versions? Contactor control, does it handle power to the contactor or just on off? I havent seen either that or can in the wiring diagrams I think. Those were very basic. I suppose it dosent have an analog input for variable regen?

Thanks for the reply, sorry for the 1000 questions :oops:
 
Hmm, i might need to look into the field weakening then. That or im completely misunderstanding how it works.

I believe the pc software can log. The phone app can do graphs too supposedly, havent really played with it much either. Was going to wait until i got it on the dyno to mess around with it.

My encoder is what id call a quadrature encoder. I believe the purpose of the contactor control is to wait until precharge has completed before automatically pulling in the main contactor. It might also trip the contactor on overcurrent. Will need to work that out myself as the manual makes no mention of it at all. It didnt even have the wiring for the plugs on the loom. Got that seperate. Still, i promise, when i get time i will put it all on here for other poor peeps frantically googling for it :lol: .

No analog input. Just throttle release and brake input. Ask whatever questions you like, thats the point of the thread 8) .

New rims arrived, fitted up some smoother tires. Last day of drag racing until sept tomorrow so ill take it down and see how it goes.

20220524_194641.jpg

Doug
 
Here is something about MTPA:
https://endless-sphere.com/forums/viewtopic.php?f=30&t=89056&start=425
I hope I was able to link the right page, it was 17 or 18 I think.
I dont really get it though, I think when you have MTPA you shouldnt really think about FW. It is just part of it, and should work automatic?

Is your controller not the same as the ones for uvw hall sensors? Is your sensor output connected to pin 27,28 and 29?
I have seen that there should be different hardware for sin cos, compared to the standard uvw.
But not that there are more variants.

What is your max voltage, and can you change it?
I have seen 115 and 118V mentioned, but I have also seen screenshots with 121,5V trip and 119 or something restore.
 
Ok, I sort of get it, but let some coffee kick in and Ill read it again. Certainly if it does do MTPA then the parameters for it are automatically set during the auto tune process. Very easy to slap a logo on an app...

I found a different manual from fardriver last night that had more information about the setting of the current curve and it does look to automatically doing field weakening. Looks like you set a param which is the maximum theoretical speed of the motor according to the battery voltage and KV, then in the % map, leaving %'s higher then 5% means it will attempt to reach those rpms. You cant really just leave it at 100% because the current will just produce excess heat after an effective value. Probably the easiest way to actually test this is once again on the dyno. I think for now I will just disable it by setting the % right after theoretical highest RPM to 5%, but it might be a good way to get around speed loss when the battery voltage gets lower. Now I have the road tires I should be able to spend some time this weekend on the dyno.

The voltages are not programmable except for the low voltage protect.


Over volt protect = 121.5V
Over volt restore = 119.5V
Low voltage restore = Low voltage protect + 2V.

Mine's the 961800.

Doug
 
Good news and bad news from the drags. Yes, this thing rips. Did multiple 1.9s 60 foots and best time was a 13.6 @ 140kph. Field weakening is definitely active and working. Bad news is i had a bit of a stuttering loss of power in the mid range, not sure why. Moved current limits up and down but no cidar. Last run i upped to maximum instead of limiting it and it died while crossing the line :cry: . Something has gone bad inside the battery. I originally build the pack for 300A peak. Im guessing ive cooked some of the small copper links on cell 4. Will have to cut it open and autopsy. Still, damn thing will power wheely half way down the strip if i let it. Thats with 11/52 gearing 8) . Ill fix the battery, set it to a peak of 300A and be content.

Doug
 
Cool :thumb:
Were you able to get fast ramp up (throttle response)?
I suppose you didnt test anything on the dyno?

dougf said:
Ill fix the battery, set it to a peak of 300A and be content.

Yea, right :lol:
Fix the weak link and run full power :wink:
 
Well, maybe a touch more now and then :twisted: . Throttle ramp is good. I pulled multiple 1.9s 60 feet on pretty tall gearing. My last run when i blew up was still a 14.0 @120kph. Short track really good on this bike.

https://youtu.be/_AFHN4xoQt4

Definitly a good combo with 961800 and qs180.

Doug
 
Back
Top